

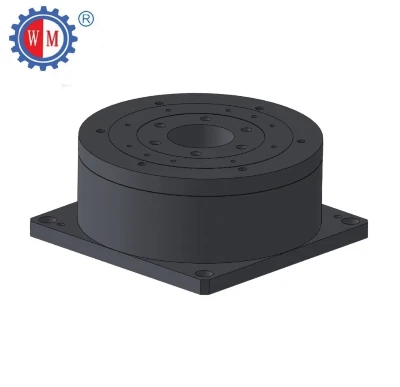


Mechanical Design & Axis Configuration
Lub motorized gimbal theem feem ntau nta ob los yog peb lub orthogonal axes -feem ntau sau npe azimuth, elevation, thiab qee zaum yob- uas sib tshuam ntawm ib qho chaw sib hloov. Qhov geometry no yog qhov teeb tsa lub cev muaj zog gimbal theem sib nrug ntawm cov txheej txheem yias - qaij units lossis stacked rotary theem. Nyob rau hauv kev xyaum, lub motorized gimbal theem xyuas kom meej tias ib tug laser beam los yog telescope kab ntawm pom nyob rau hauv lub hauv paus ntawm complex maneuvers. Cov neeg tsim khoom tsim cov theem motorized gimbal nrog siab - khov bearings, ncaj qha - tsav motors, los yog precision stepper / servo ua ke, thiab siab - daws teeb meem encoders kom ua tiav sub- thib ob positioning. Load peev xwm rau lub motorized gimbal theem ntau los ntawm ob peb grams rau ultra{11}}lub teeb optical mounts mus rau ob peb kilograms rau loj dua aerospace payloads, ua rau motorized gimbal theem ntau yam thoob scale.
Kev Txhim Kho Keeb Kwm & Kev Txawj Ntse
Keeb kwm, lub motorized gimbal theem hloov zuj zus los ntawm thaum ntxov mechanical gimbals siv nyob rau hauv naval stabilization thiab aircraft tus cwj pwm tswj. Kev hloov pauv mus rau cov qauv tsav tsheb nrawm nrawm hauv lub xyoo pua nees nkaum nrog kev nce ntawm photonics thiab semiconductor fabrication. Niaj hnub no, lub motorized gimbal theem suav nrog brushless DC motors, piezoelectric xaiv rau siab tshaj - kev daws teeb meem daim ntawv thov, thiab advanced firmware uas them rau thermal drift thiab backlash. Thaum xaiv lub motorized gimbal theem, engineers ntsuam xyuas torque - rau - inertia ratios, nyob rau lub sij hawm, thiab bidirectional repeatability. Lub motorized gimbal theem kuj yuav tsum tau raws li ib puag ncig xav tau xws li lub tshuab nqus tsev compatibility rau qhov chaw simulation chambers los yog cleanroom ntsuam xyuas rau semiconductor tshuaj ntsuam.


Daim Ntawv Thov Kev Lag Luam tseem ceeb
Daim ntawv thov ntawm motorized gimbal theem kev tiv thaiv, aerospace, kev kho mob duab, thiab kev tshawb fawb lub chaw soj nstuam. Hauv kev taw qhia - lub zog hluav taws xob, lub tshuab hluav taws xob gimbal theem steers siab - lub zog laser kab teeb nrog qhov tseeb heev kom tswj lub hom phiaj ntsuas qhov ntev. Lub cev muaj zog gimbal theem yog qhov tseem ceeb sib npaug hauv cov chaw ntsuas satellite, qhov uas nws rov ua dua kev hloov pauv tus cwj pwm thaum lub caij lub tshuab nqus tsev thermal. Optical kev sib txuas lus terminals nyob ntawm lub motorized gimbal theem kom tau thiab taug qab ceev ceev- txav satellites nyob rau hauv qis-Lub ntiaj teb orbit. Nyob rau hauv lub semiconductor sector, lub motorized gimbal theem aligns wafers thiab reticles thaum lub sij hawm lithography txheej txheem uas xav tau nanometer -theem overlay raug. Txawm tias nyob rau hauv biomedical instrumentation, lub motorized gimbal theem enables confocal microscopy theem los luam theej duab cov ntaub so ntswg yam tsis qhia kev co los yog drift.
Tswj, Synchronization & System Integration
Ib qho ntawm qhov zoo tshaj plaws ntawm lub motorized gimbal theem yog nws lub peev xwm los synchronize nrog lwm tus ua rau thiab tawm tswv yim loops. Niaj hnub nimno motion controllers ua ke nrog lub motorized gimbal theem los txhawb trapezoidal, S-khoov, los yog kev cai tshaj tawm profiles uas txo jerk thiab overshoot. Cov software suites tso cai rau cov neeg siv los ua cov txheej txheem motorized gimbal ntawm LabVIEW, Python, lossis tus tswv APIs, streamlining automation hauv cov kab ntau lawm. Lub motorized gimbal theem kuj txhawb daisy- chaining nrog linear theem, tsim tag nrho rau -degree- ntawm -txoj kev ywj pheej thaum ua ke nrog hexapods lossis XYZ platforms. Qhov no modularity piav qhia vim li cas lub motorized gimbal theem tshwm nyob rau hauv yuav luag txhua qhov siab -kawg photonics workbench.

Cov ntsiab lus tseem ceeb
Thaum ntsuas lub motorized gimbal theem rau ib qhov project, cov ntsiab lus tseem ceeb muaj xws li angular range, siab tshaj plaws ceev, daws teeb meem, repeatability, thiab wobble. Ib tug raug siab -kawg motorized gimbal theem yuav muab ± 90℃nyob rau hauv lub puab axis thiab ± 45℃ntawm sab axis, nrog speeds mus txog 30 degrees ib ob thiab kev daws teeb meem mus txog 0.0001℃. Lub motorized gimbal theem lub encoder tawm tswv yim-txawm hais tias incremental los yog kiag li- xyuas kom kaw- lub voj kev ua haujlwm uas kho rau cov khoom tsis zoo. Payload{11}}induced deflection yuav tsum tau txo; yog li ntawd, lub motorized gimbal theem feem ntau suav nrog finite-element tsom xam thaum lub sij hawm tsim kom Abbe yuam kev hauv qab qhov ntsuas tau. Rau lub tshuab nqus tsev los yog cryogenic ib puag ncig, lub motorized gimbal theem siv tshwj xeeb lubricants thiab cov ntaub ntawv uas tiv thaiv outgassing los yog thermal contraction teeb meem.
Integration & Calibration
Kev sib koom ua ke nrog cov theem motorized gimbal yog niaj hnub hais los ntawm kev tswj hwm cable thiab EMI shielding. Vim hais tias lub motorized gimbal theem rotates tsis tu ncua nyob rau hauv ib co configurations, plam rings los yog wireless cov ntaub ntawv kis tau tus mob kom lub zog thiab cov teeb liab tsis zoo. Calibration routines rau lub motorized gimbal theem muaj xws li laser autocollimators los yog interferometers rau daim ntawv qhia thiab them rau tej yam uas tsis muaj residual. Thaum calibrated, lub motorized gimbal theem tswj kav ntev - lub sij hawm stability, feem ntau tshaj 24 teev ntawm kev khiav hauj lwm tas mus li yam tsis muaj recalibration. Qhov kev ntseeg siab no ua rau lub cev muaj zog gimbal theem qaum ntawm 24/7 cov cuab yeej tsim khoom hauv fiber ntau- optic tivthaiv kev tsim khoom.
Drive Technologies & Advanced Control
Saib tob rau hauv cov thev naus laus zis, theem motorized gimbal tuaj yeem siv ob lub motors stepper rau tus nqi -zoo qhib- voj tswj lossis servo motors rau siab - kev ua haujlwm zoo. Piezo-tsav motorized gimbal theem variants ua tiav nanometer- theem angular cov kauj ruam nrog lub sij hawm teb nyob rau hauv ib millisecond, zoo tagnrho rau active vibration tshem tawm los yog ceev beam steering. Hybrid designs ua ke ntxhib stepper suab nrog kev hloov piezo zoo nyob rau hauv tib lub motorized gimbal theem sib dhos. Advanced controllers tam sim no embed tshuab-kawm algorithms uas kwv yees thiab preempt thermal lossis load-induced drift, ntxiv txhim kho lub motorized gimbal theem lub hnab ntawv kev ua tau zoo.
Aerospace & Autonomous Vehicle Testing
Nyob rau hauv aerospace sector, lub motorized gimbal theem simulates davhlau dynamics rau inertial navigation system kuaj. Engineers mount gyroscopes los yog lub hnub qub trackers ntawm lub motorized gimbal theem thiab muab lawv mus rau qhov tseeb suab, yob, thiab yaw profiles. Lub cev muaj zog gimbal theem qis wobble thiab siab tawv kom ntseeg tau tias cov ntaub ntawv xeem kom raug cuam tshuam txog - tus cwj pwm hauv ntiaj teb. Ib yam li ntawd, nyob rau hauv kev tsim kho tsheb tsis muaj zog, lub motorized gimbal theem calibrates LiDAR thiab lub koob yees duab sensors los ntawm cheb lawv los ntawm cov qauv angular meej uas ua raws li txoj kev. Lub motorized gimbal theem yog li accelerates txoj kev loj hlob cycles thaum txo kev cia siab rau kim sab nraum zoov lem.
Cov ntawv thov kho mob & tshawb fawb
Cov cuab yeej siv kho mob suav nrog cov theem motorized gimbal rau hauv kev phais neeg hlau thiab cov cuab yeej kuaj mob. Lub cev muaj zog gimbal theem muab kev sib tw, tshee tshee -txoj kev ywj pheej xav tau rau laser-raws li kev phais qhov muag lossis kev xa hluav taws xob ncaj qha. Vim hais tias tus neeg mob kev nyab xeeb nyob ntawm sub-millimeter raug, lub motorized gimbal theem tau tsim- nyob rau hauv kev ruaj ntseg interlocks thiab redundant encoders yog tsis muaj -nej sib tham. Hauv kev tshawb fawb hauv tsev kawm qib siab, theem motorized gimbal txhawb nqa cov kev sim xws li quantum optics mus rau gravitational nthwv dej nrhiav pom, qhov twg txawm tias qhov me tshaj qhov kev tsis sib haum xeeb tuaj yeem ua tsis tau.
Xaiv & Customization
Xaiv txoj cai motorized gimbal theem yuav tsum ntsuas qhov ua tau zoo, tus nqi, thiab lub sijhawm ua haujlwm. Nkag mus-theem motorized gimbal theem qauv los ntawm cov neeg muag khoom tsim muaj cov kev daws teeb meem zoo rau kev qhia chaw kuaj mob, thaum lub tshuab hluav taws xob zoo tshaj plaws gimbal theem tshuab nrog cov ntsuas ntsuas ua haujlwm xa cov ultra- qhov tseeb xav tau los ntawm lub teb chaws kuaj. Cov neeg yuav khoom yuav tsum tau thov cov ntaub ntawv ntxaws ntxaws, thib peb-cov ntaub ntawv xeem thib peb, thiab cov qauv ua qauv ua ntej ua rau lub cev muaj zog gimbal theem. Customization xaiv rau lub motorized gimbal theem-xws li kev cai mounting interfaces, ncua kub ntau yam, los yog hluav taws xob- hardened electronics- ntxiv nthuav nws applicability.
Kev tu thiab kev cia siab
Kev saib xyuas ntawm motorized gimbal theem yog ncaj nraim thaum ua raws li cov chaw tsim khoom cov lus qhia. Lub sij hawm lubrication ntawm bearings, kev txheeb xyuas ntawm encoder alignment, thiab firmware hloov tshiab kom lub motorized gimbal theem ua hauj lwm ntawm lub ncov efficiency. Feem ntau motorized gimbal theem units yog tsim los rau ntau lab lub voj voog, nrog MTBF cov nuj nqis tshaj 50,000 teev nyob rau hauv ib txwm kuaj mob. Thaum lub sijhawm poob qis yuav tsum tau txo qis, cov qauv tsim qauv tso cai hloov pauv sai ntawm motorized gimbal theem tsav modules yam tsis tau hloov kho tag nrho cov tsheb ciav hlau kho qhov muag.
Yav Tom Ntej Trends & Sustainability
Yav tom ntej tiam sis taw tes rau smarter, ntau compact motorized gimbal theem tsim. Kev koom ua ke ntawm onboard ntug xam yuav tso cai rau lub motorized gimbal theem ua tiag tiag - lub sij hawm txoj kev optimization thiab kev sib tsoo kom tsis txhob tsis muaj lwm yam controllers. Kev sib txuas wireless thiab IoT kev sib raug zoo yuav ua rau kev saib xyuas tej thaj chaw deb ntawm lub cev muaj zog gimbal theem thoob plaws ntiaj teb cov chaw. Cov txheej txheem tsim khoom ntxiv tau txo qhov hnyav ntawm lub cev muaj zog gimbal theem thaum nce nws qhov tawv nqaij - rau - qhov hnyav piv, qhib qhov muaj peev xwm tshiab rau qhov chaw txav tau yooj yim- cov tshuab siv tau. Raws li photonics thiab quantum technologies ua ntej, lub motorized gimbal theem yuav evolve kom tau raws li qhov xav tau rau txawm finer daws teeb meem thiab ceev teb lub sij hawm.
Sustainability kev txiav txim siab tseem tab tom tsim cov tiam tom ntej ntawm lub cev muaj zog gimbal theem. Lub zog- lub cev muaj zog thiab cov khoom siv rov ua dua tshiab tau dhau los ua tus qauv, txo qis cov pa roj carbon hneev taw ntawm cov chaw uas siv ntau ntau lub tshuab hluav taws xob gimbal theem. Cov neeg tsim khoom tam sim no muab cov kev hloov kho tshiab thiab hloov kho motorized gimbal theem cov kev pab cuam uas txuas ntxiv cov khoom lag luam thiab txo cov khoom siv hluav taws xob tsawg. Cov kev pib no ua kom ntseeg tau tias cov theem motorized gimbal tseem yog ob qho tib si thev naus laus zis thiab ib puag ncig lub luag haujlwm.
Xaus
Nyob rau hauv cov ntsiab lus, lub motorized gimbal theem sawv cev rau lub pinnacle ntawm precision angular tswj nyob rau hauv lub dav precision instruments ecosystem. Los ntawm thawj lub tswv yim los ntawm ntau xyoo ntawm kev pab cuam, lub motorized gimbal theem txuas ntxiv ua kom muaj kev sib tw uas zoo li niaj hnub siv tshuab. Cov kws tsim txuj ci uas paub txog qib motorized gimbal tau txais kev sib tw hauv kev tsim cov tshuab uas xav tau qhov tseeb tshaj plaws thiab kev ntseeg siab. Raws li kev lag luam thawb cov ciam teb ntawm qhov ua tau, theem motorized gimbal yuav nyob twj ywm nyob rau hauv pem hauv ntej, ntsiag to powering lub nrhav ntawm tag kis. Txawm hais tias optimizing ib qho kev tshawb fawb kev teeb tsa lossis kev ntsuas tag nrho cov kab ntau lawm, lub tshuab hluav taws xob gimbal theem muab cov kev ua tau zoo uas xav tau. Lub cev muaj zog gimbal theem yog, yam tsis muaj lus nug, lub hauv paus pob zeb thev naus laus zis uas yuav txuas ntxiv mus ntxiv nrog rau qhov puas tau - nce kev xav tau ntawm siab - kev siv thev naus laus zis thoob ntiaj teb.


